Compliant Gripper Design
Robotic Design - 2024
Articulated Compliant Gripper
The MATE ROV Competition is an underwater robotics competition where a remotely operated submersible must measure and manipulate objects 15' below the surface of the water. I have been on Rose-Hulman’s team for four years.
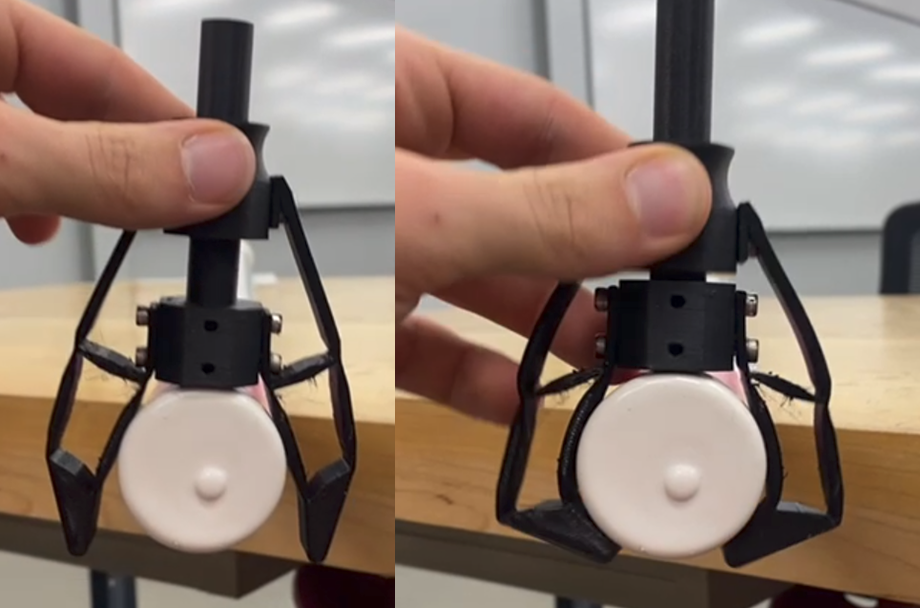
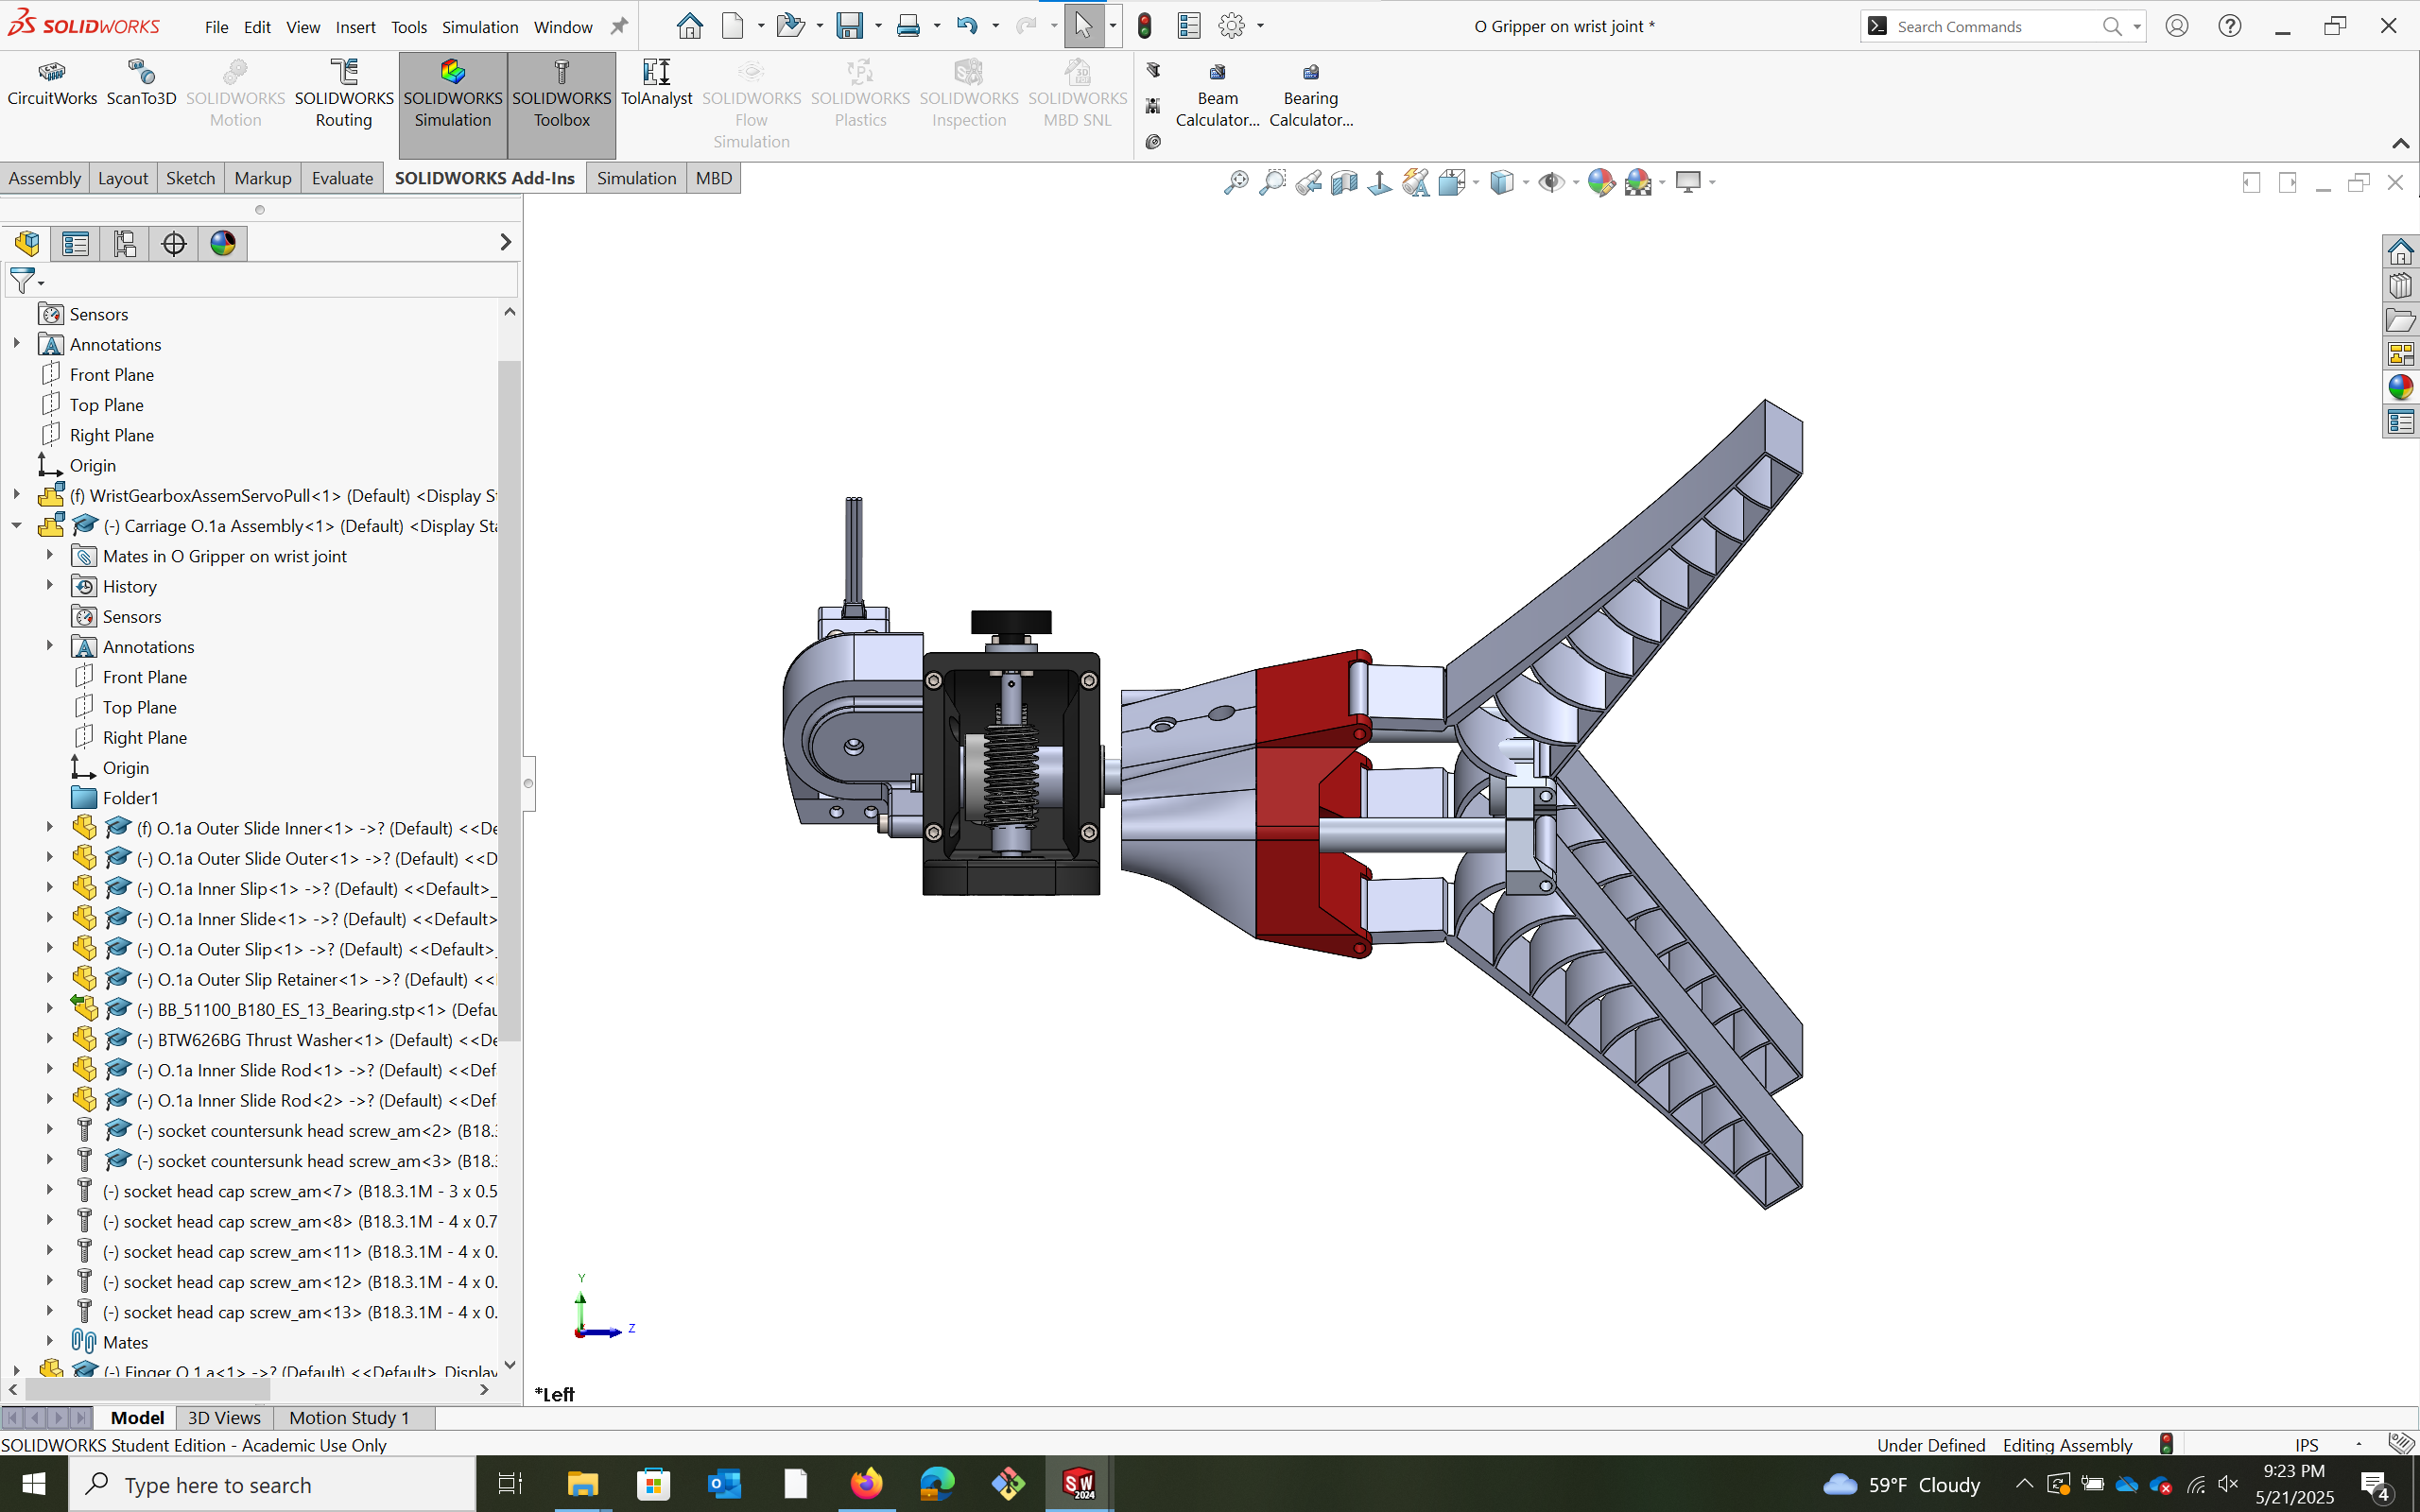
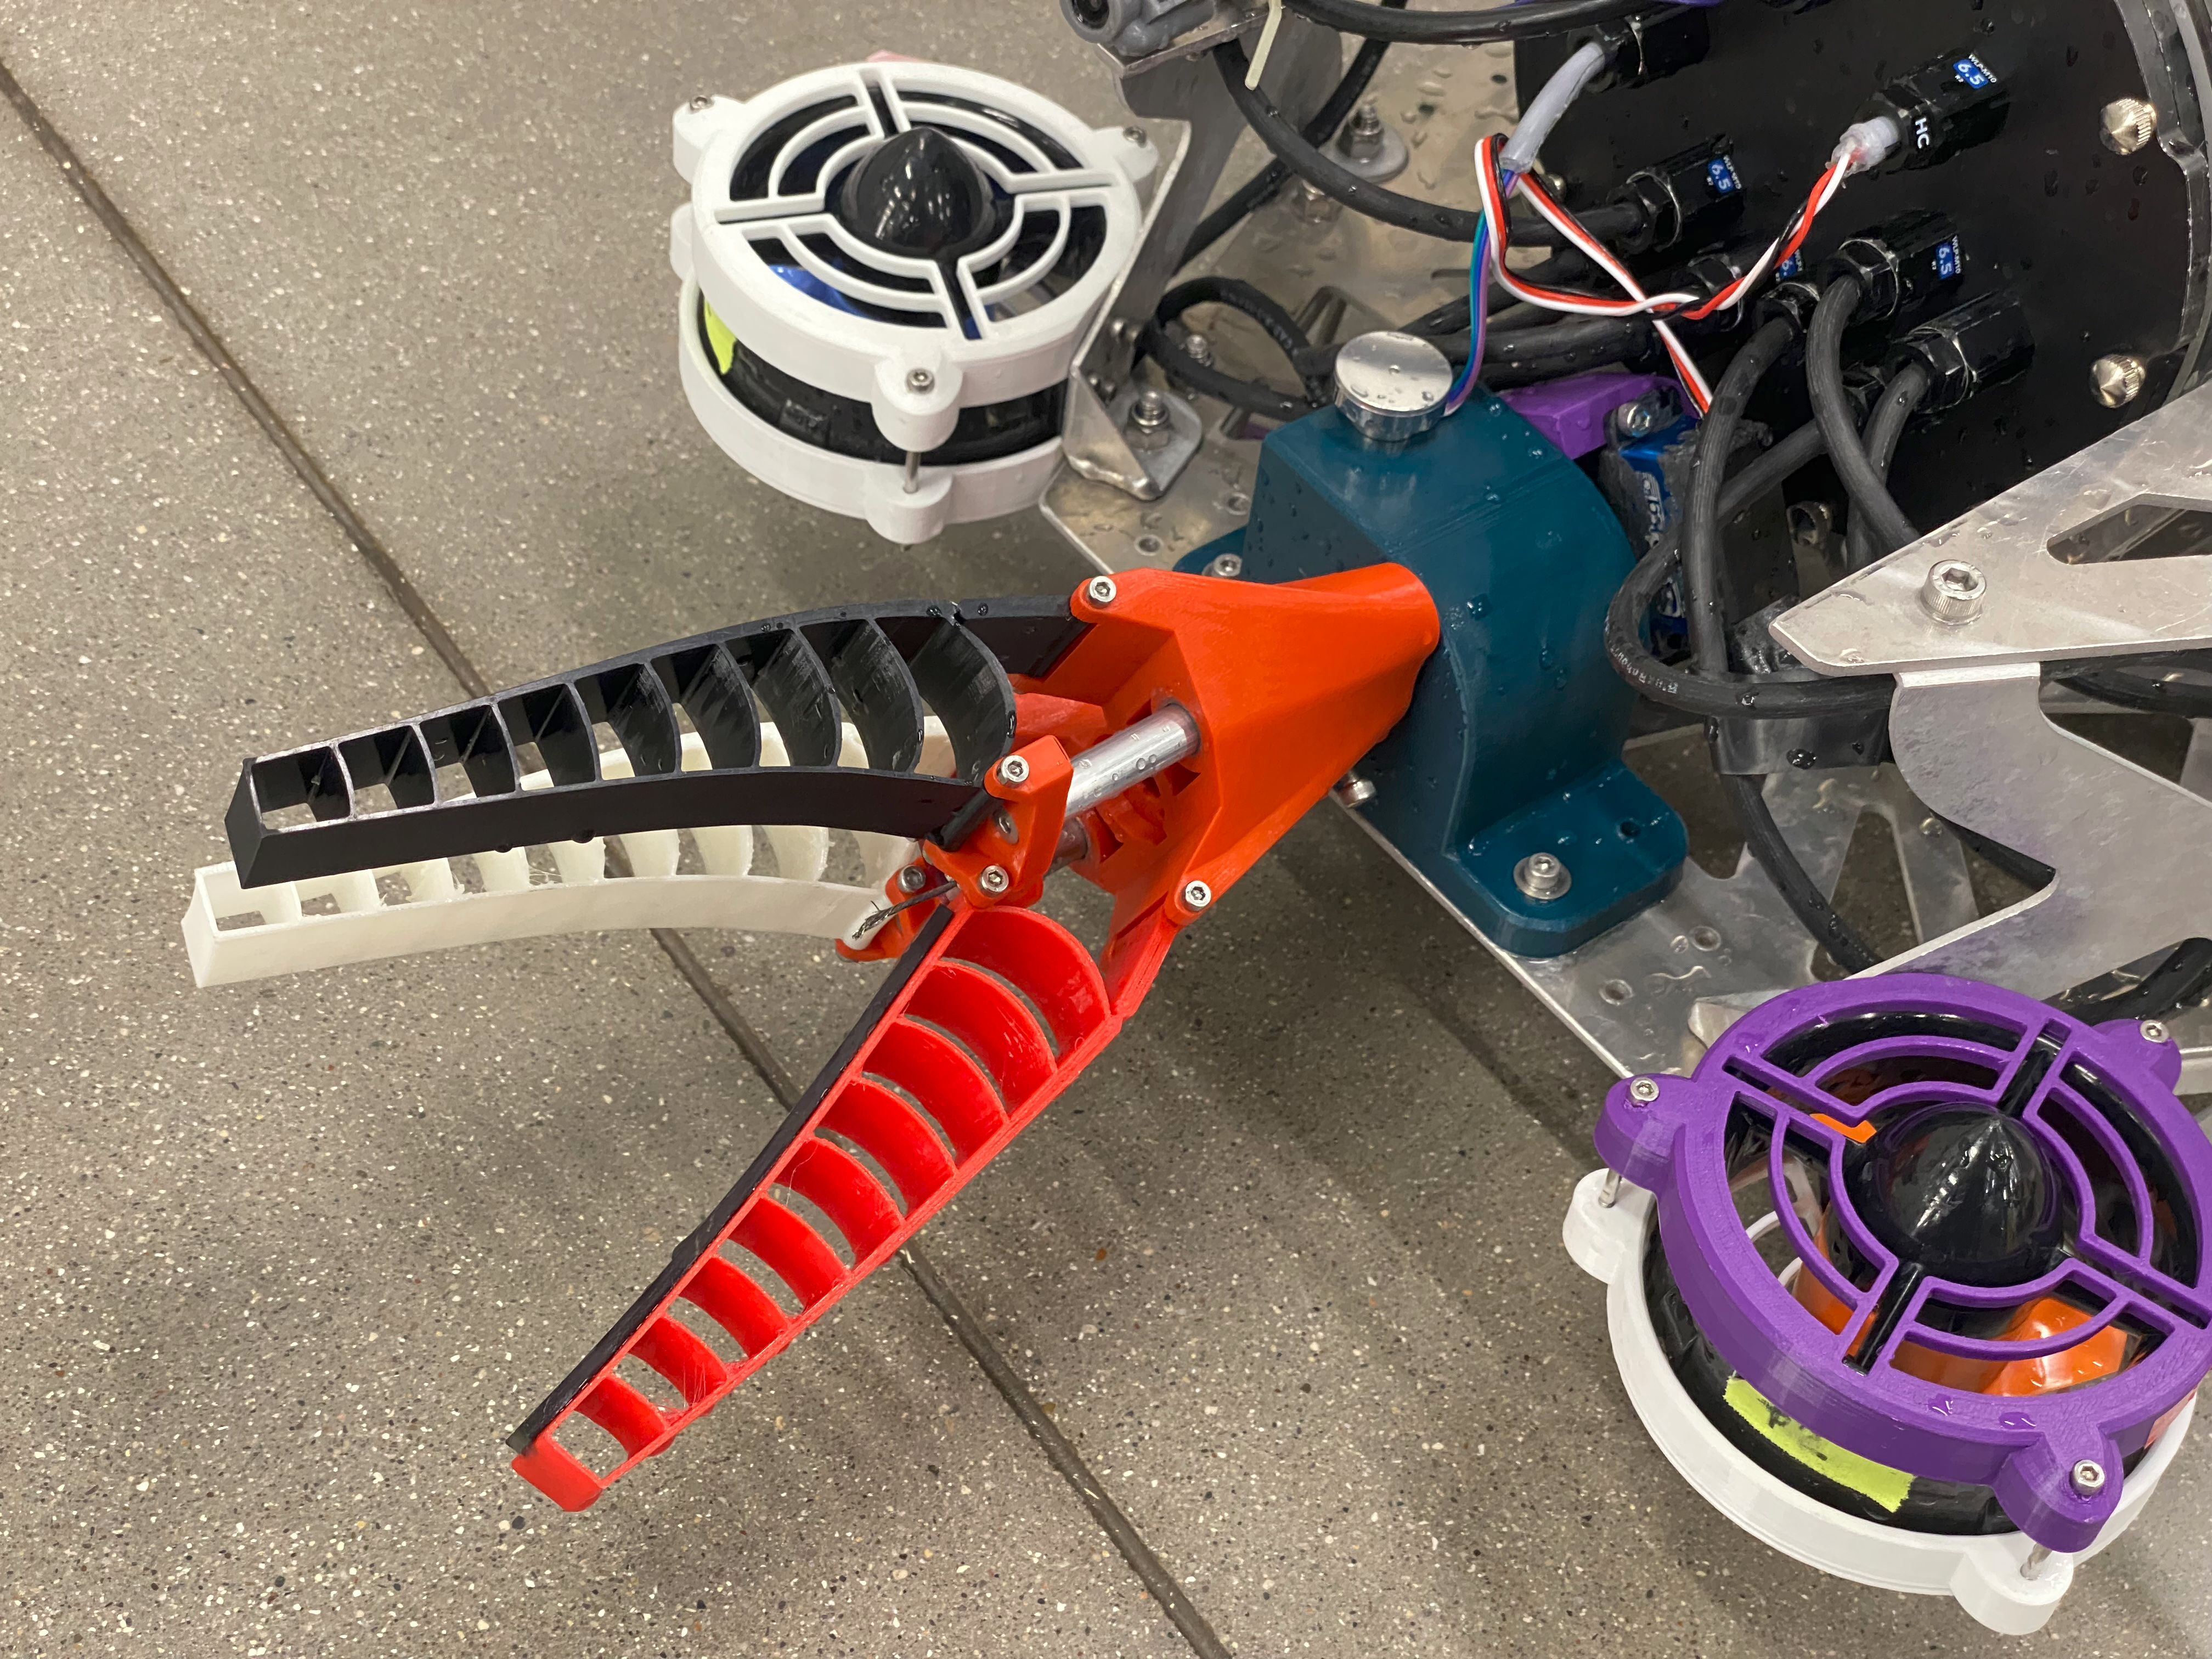
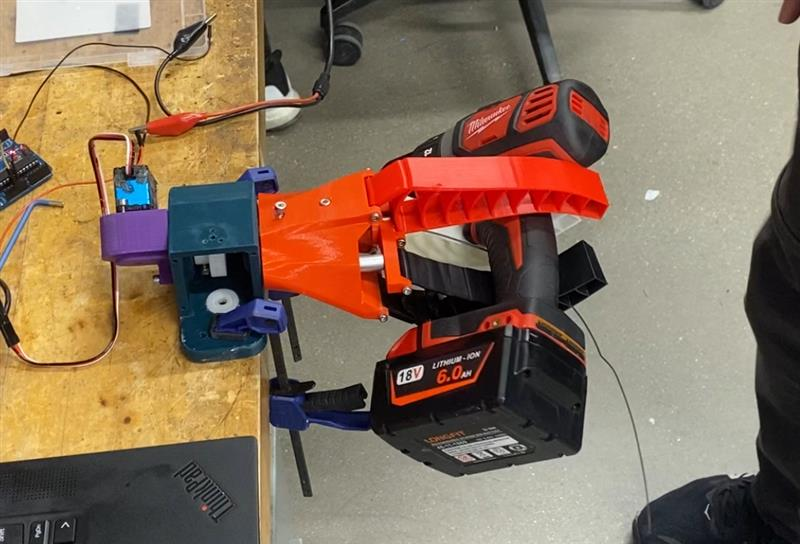
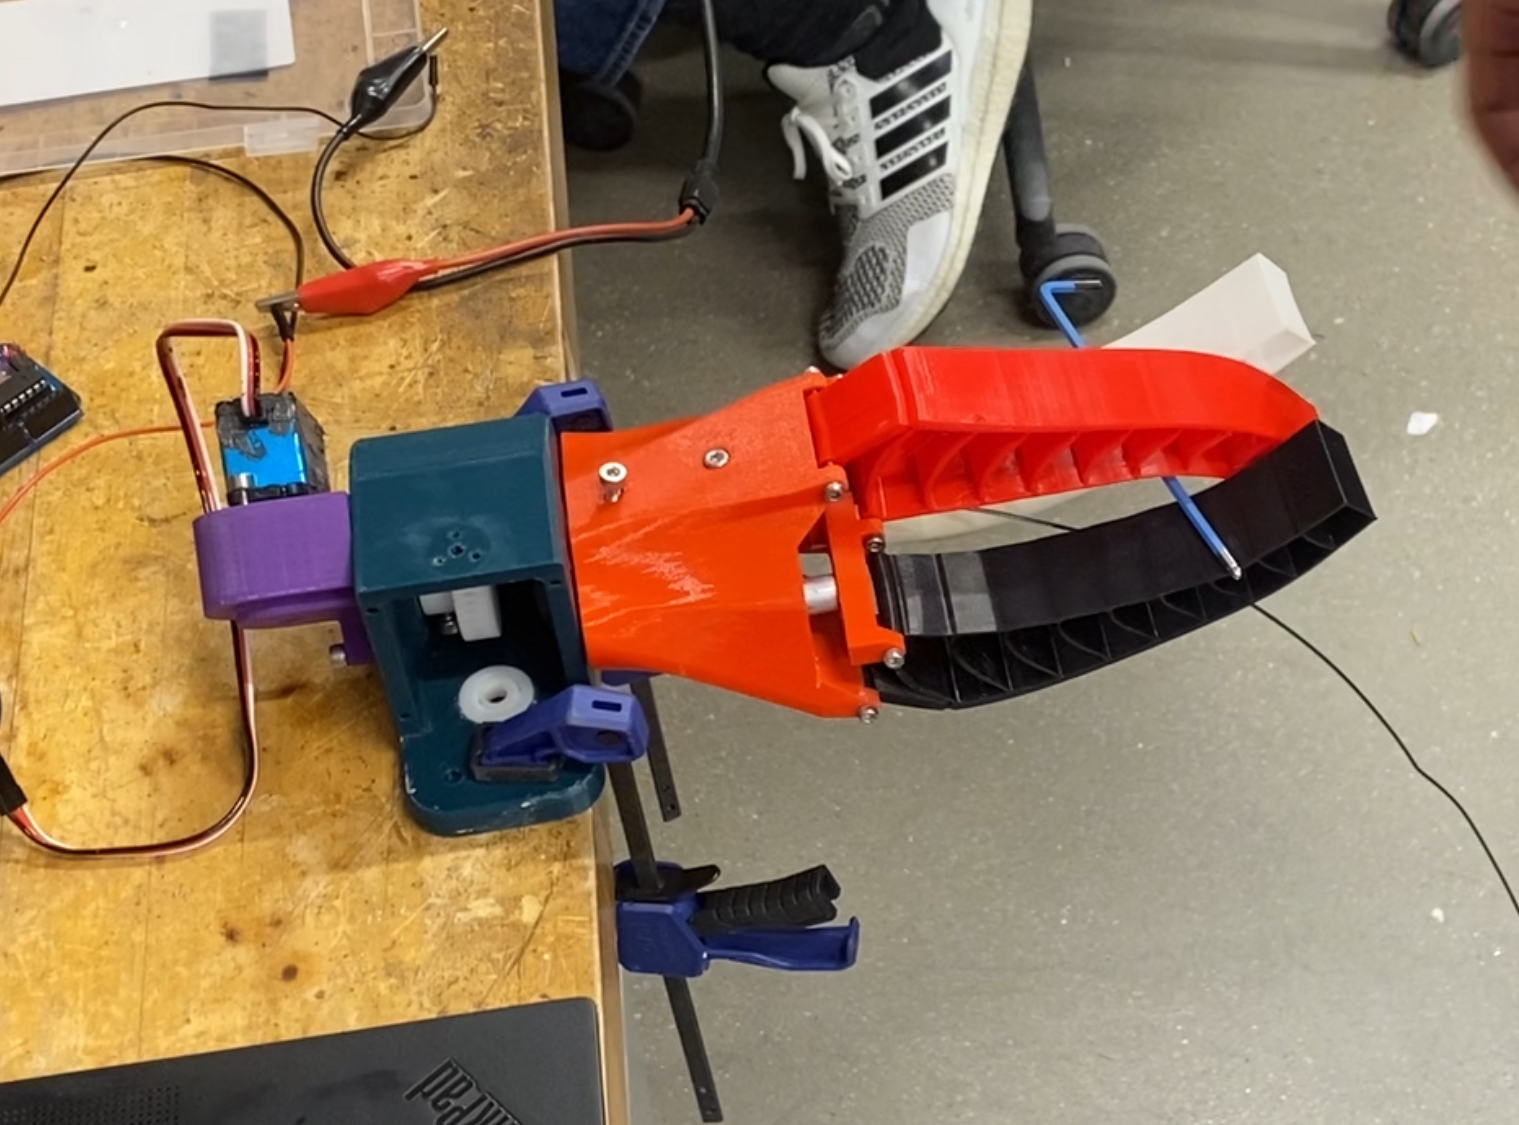
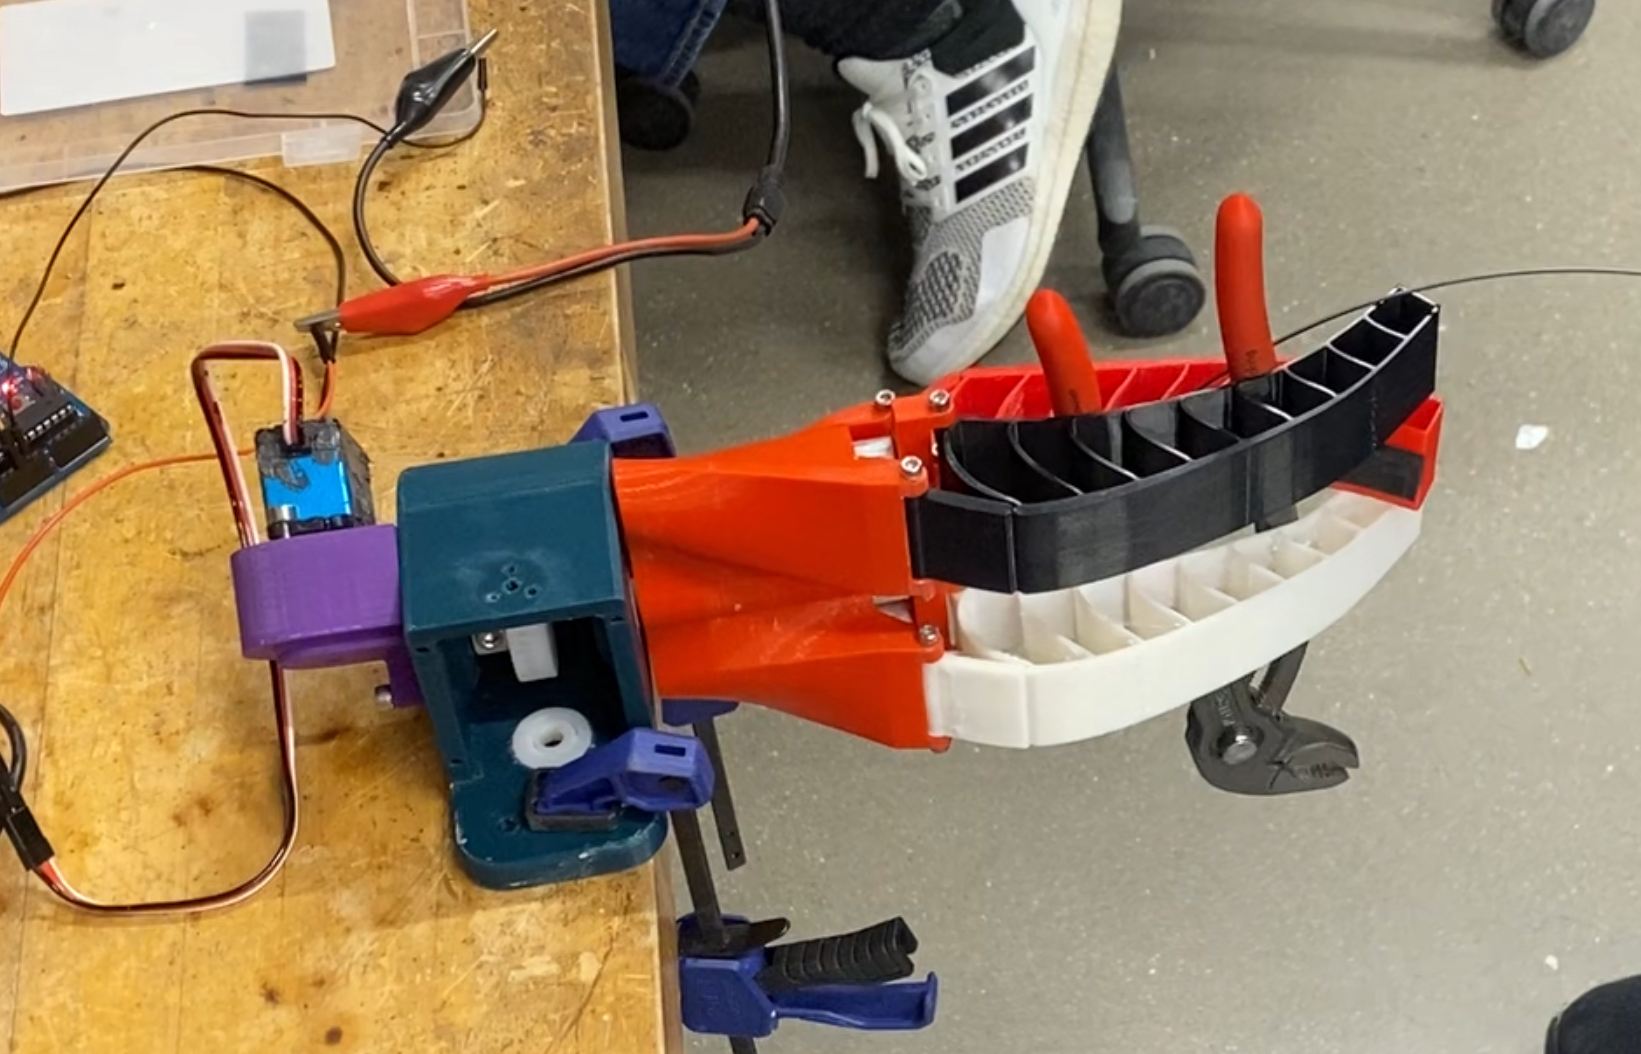
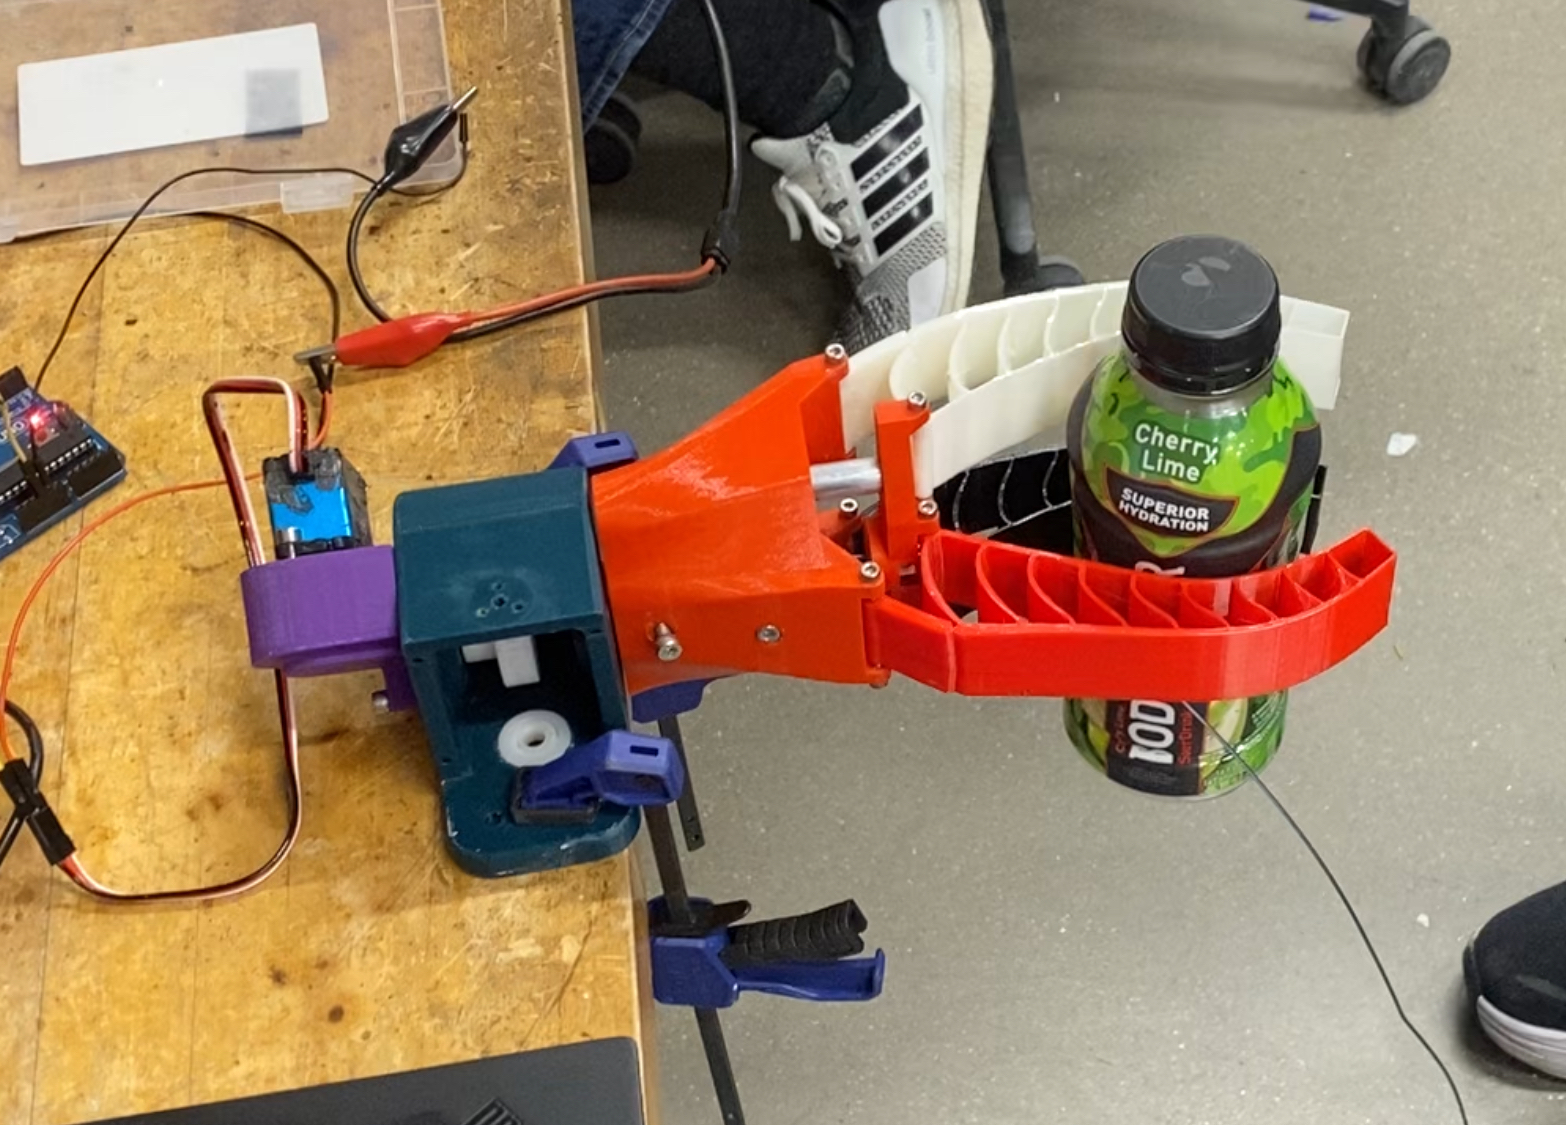
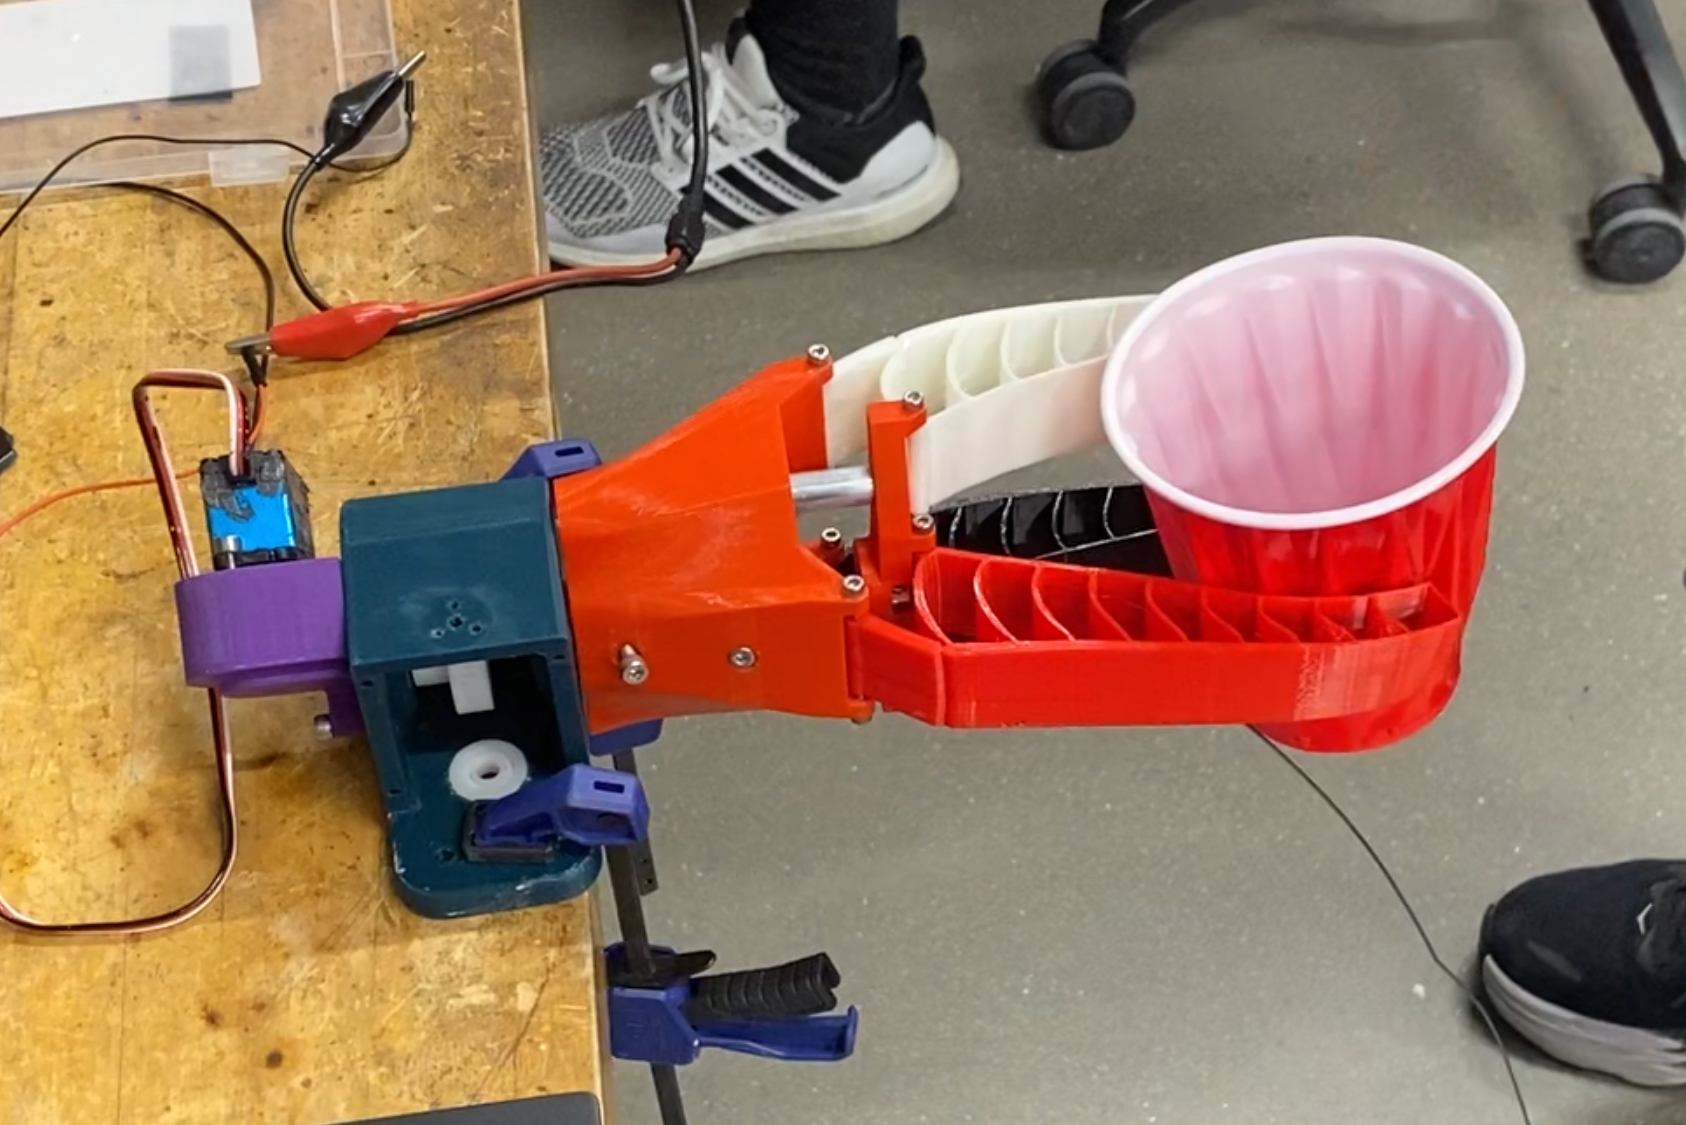
My first two years on the team, I designed a durable, performant, and easy-to-manufacture compliant gripper system. The gripper is cable-actuated; a servo winch pulls a bicycle shifter cable, which runs through a wrist joint along the axis of rotation and pulls the gripper closed via a bearing. This allows for unlimited rotation of the gripper in either direction.
Its three-finger design can grasp objects of various sizes, and its compliant fingers distribute gripping force, allowing it to handle delicate objects (Red Solo Cup?) without damaging them. During our competition, we successfully manipulated all underwater game elements using this gripper.
Compliant Gripper Finger Design
MATE Compliant Gripper Design: Continuous Motion Estimation
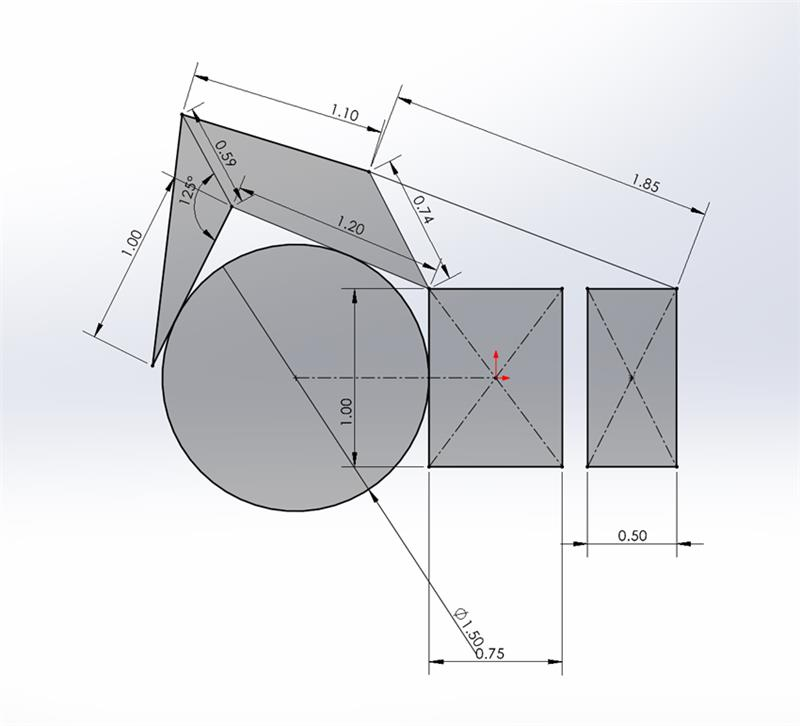
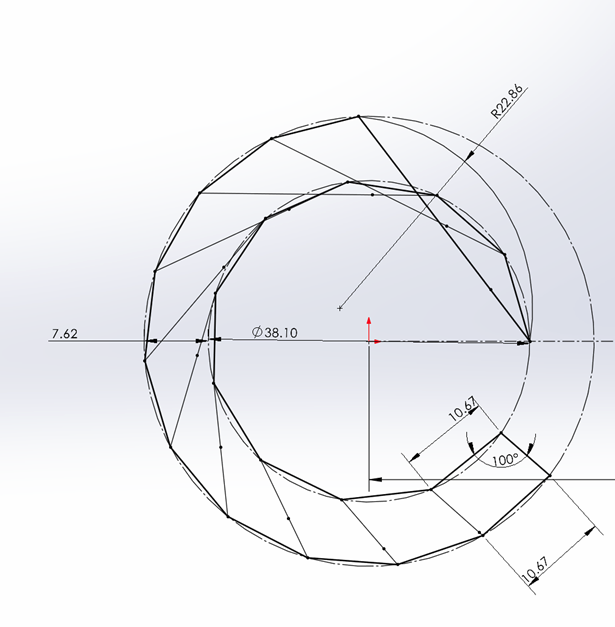
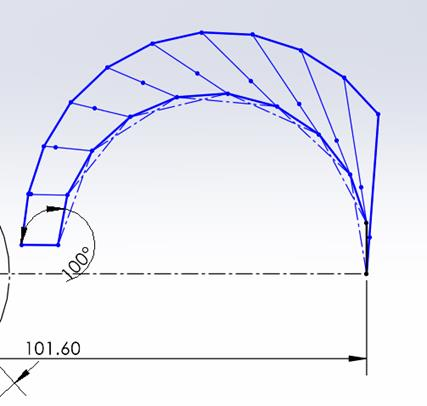
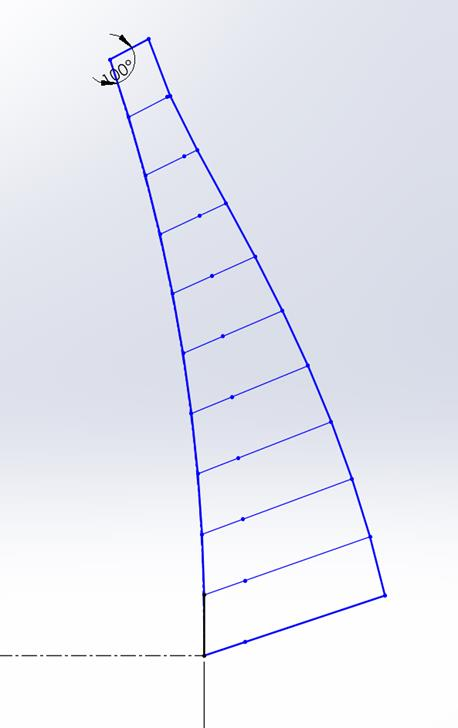
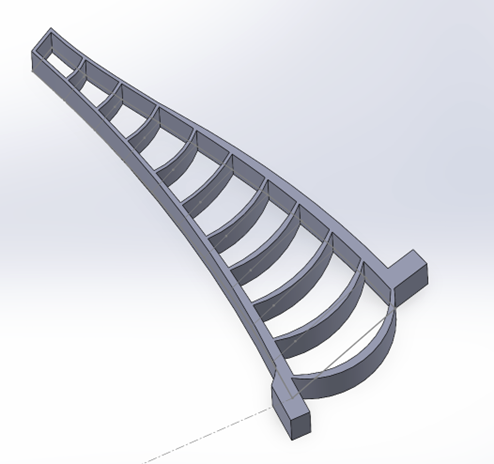
I designed the fingers of the MATE Compliant Gripper in SOLIDWORKS by modeling their shape wrapped around a circular object, and then unwrapping that shape. This results in geometry that naturally curls around objects when it grabs them, distributing the gripping force.
Rigid Mechanism Estimation
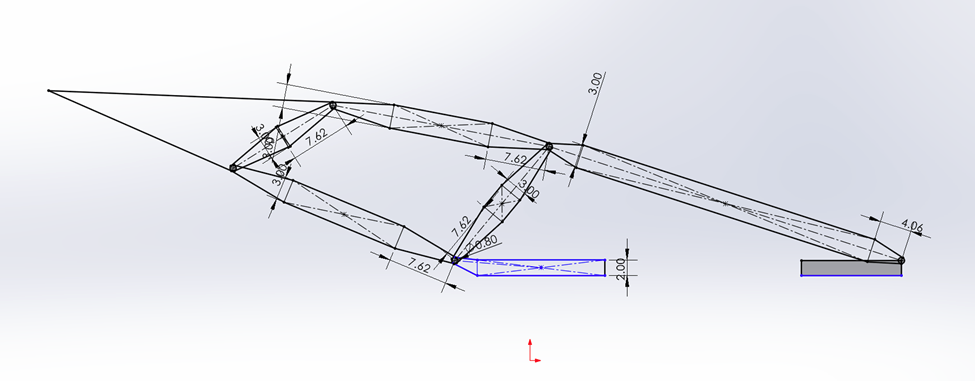
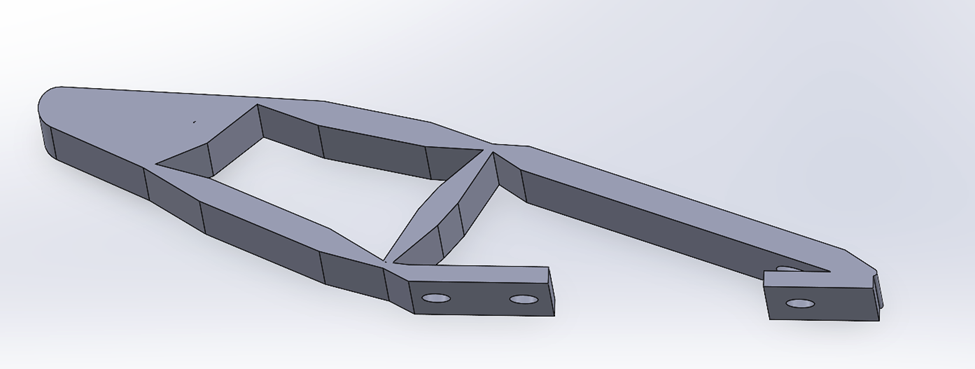
I implemented an alternate design methodology for compliant mechanisms that mimic rigid-body mechanisms. This approach involves replacing rigid linkages with thick sections and joints with thin “hinge” areas. This methodology is well suited for replacing sprung rigid mechanisms, since the material’s deformation acts as a spring pushing it back to its manufactured position.